
People
Engineers, scientists, and clinicians working together on closed-loop neurorehabilitation at the Lampe Joint Department of Biomedical Engineering, NC State and UNC-Chapel Hill.
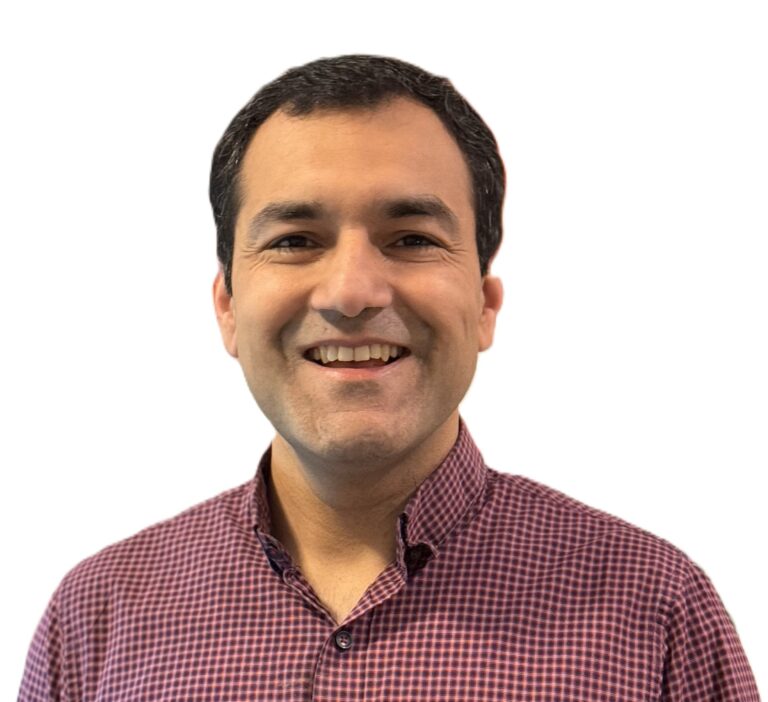
Nitin Sharma, PhD
Professor
Lampe Joint Department of Biomedical Engineering · NC State University & UNC-Chapel Hill
Nitin Sharma received his B.E. in Industrial Engineering from Thapar Institute of Engineering and Technology, India, in 2004, and his M.S. (2008) and Ph.D. (2010) in Mechanical Engineering from the University of Florida. He was an Alberta Innovates–Health Solutions Postdoctoral Fellow in the Department of Physiology at the University of Alberta. From 2012 to 2019 he was on the faculty of Mechanical Engineering and Materials Science at the University of Pittsburgh, where he was promoted to Associate Professor in 2018. He joined the Joint Department of Biomedical Engineering at NC State and UNC-Chapel Hill in 2019 and was promoted to Professor in 2026.
His research focuses on the modeling, optimization, and control of functional electrical stimulation (FES) and hybrid exoskeletons that combine FES with powered exoskeletons, and on using ultrasound imaging-derived sensing to address human–robot interaction problems in rehabilitation. His work is funded by NSF and NIH.
- NIBIB Trailblazer Award (2021)
- IEEE Control Systems Technology Award (2019)
- NSF CAREER Award (2018)
- O. Hugo Schuck Best Application Paper, ACC (2008)
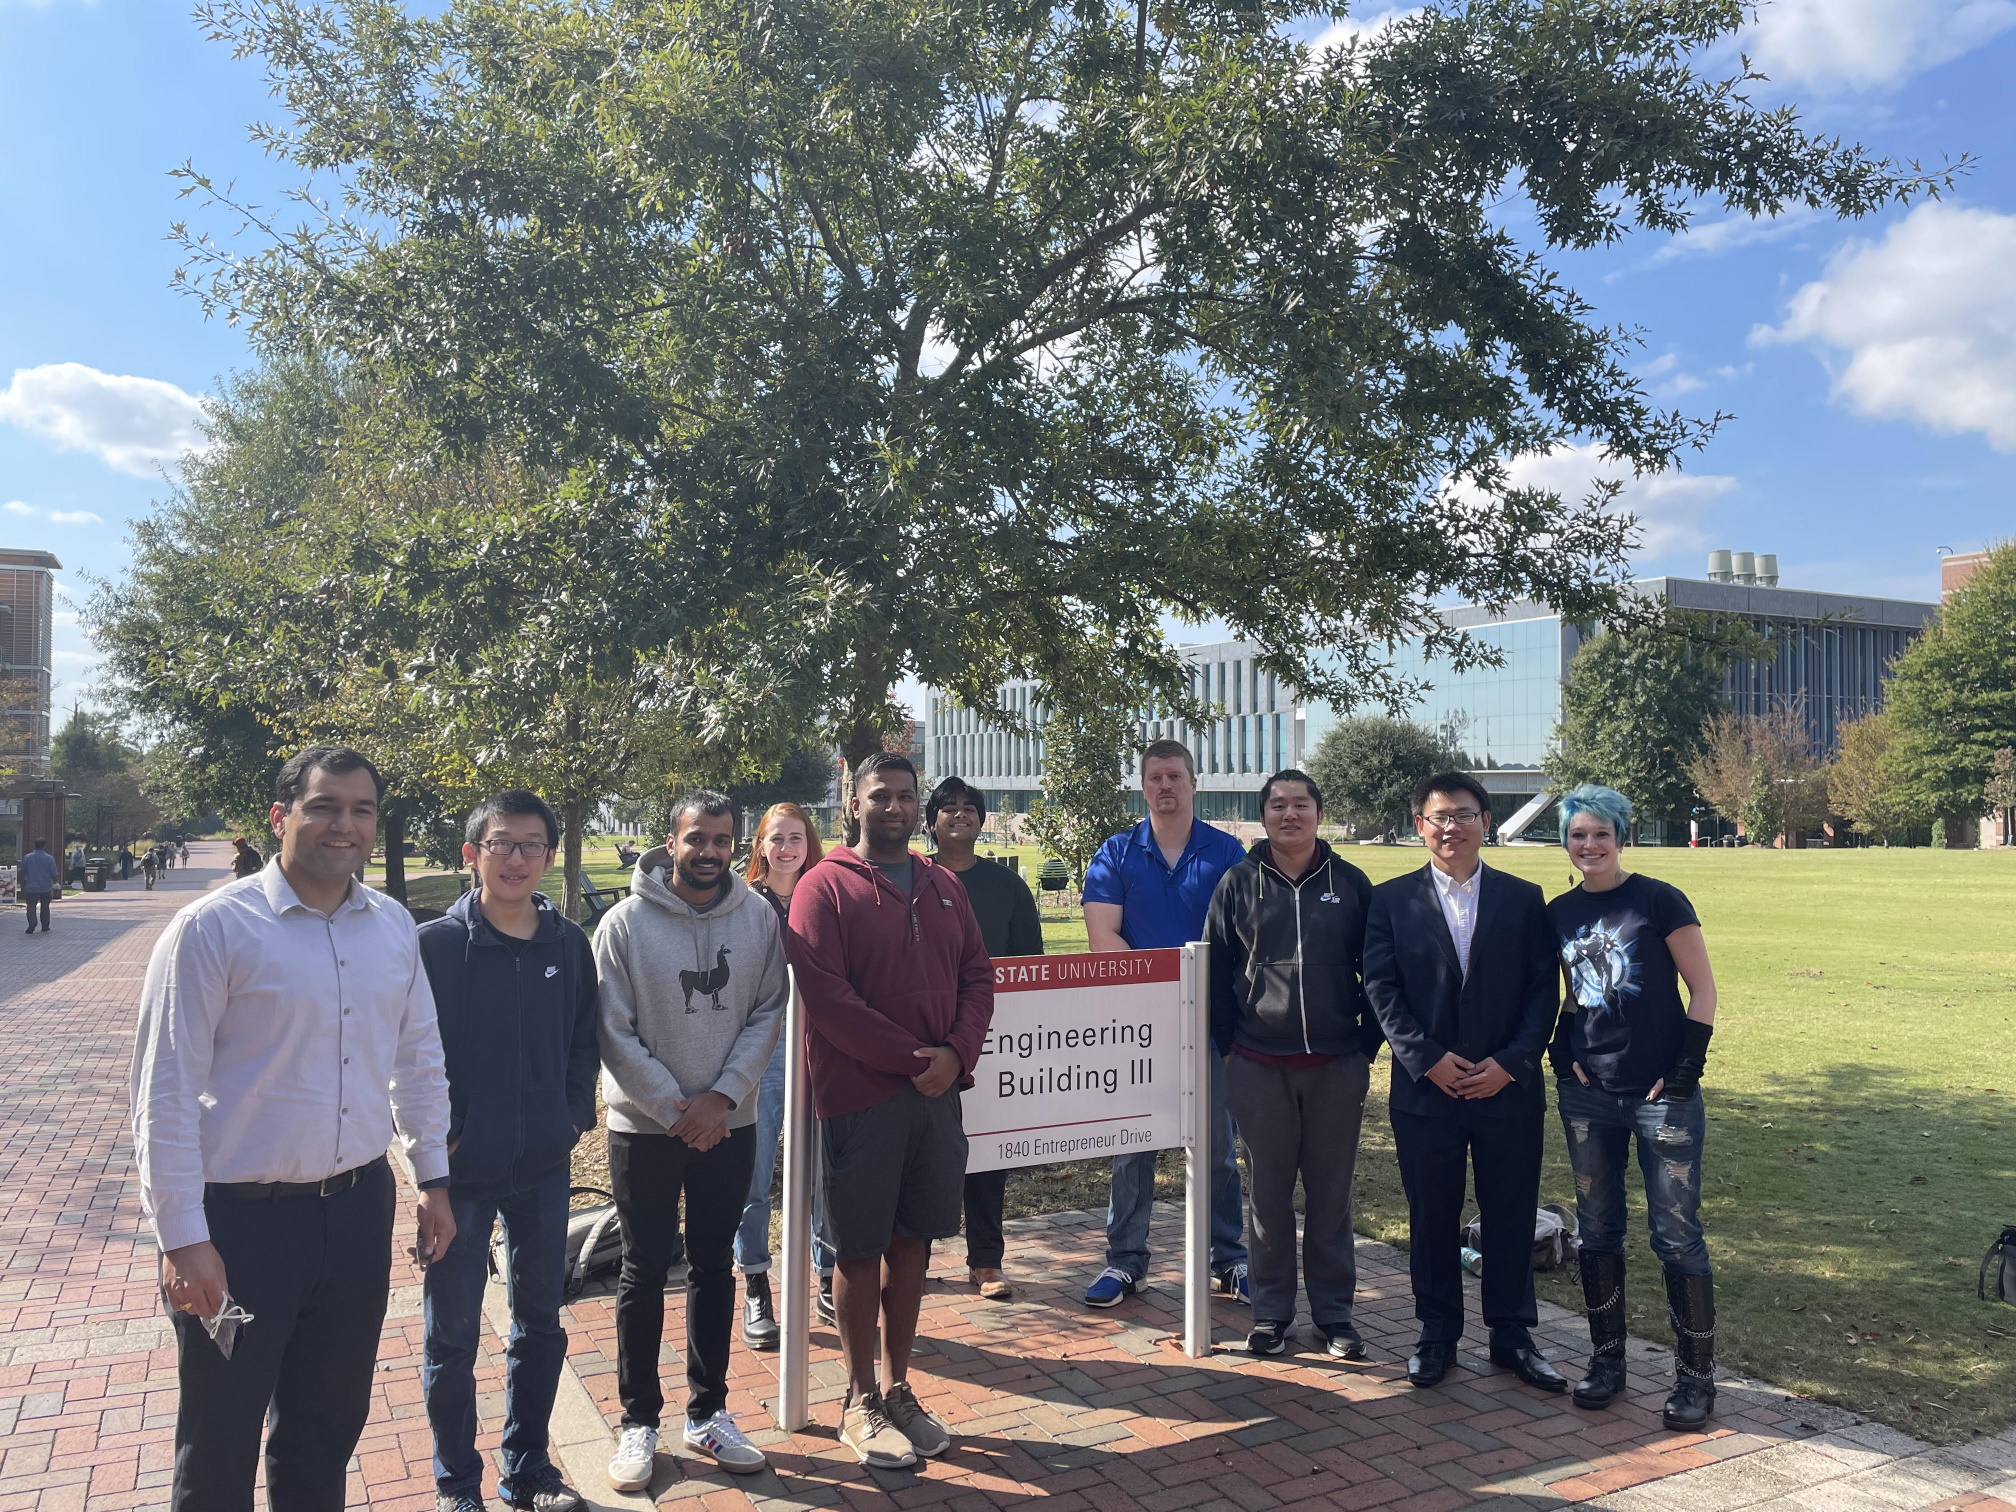


Postdocs
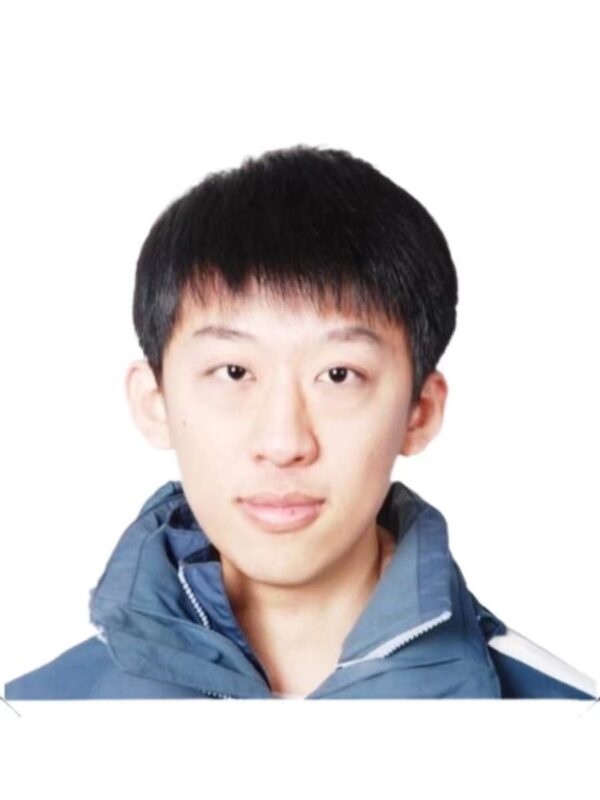
Xiangming Xue, PhD
Postdoctoral Research Associate
B.S., China University of Mining and Technology, Beijing (2012); M.S., California State University, Long Beach (2015); Ph.D., Mechanical Engineering, NC State (2019). Previously a controls engineer for electrified powertrains. Co-advised by Dr. Xiaoning Jiang, he works on control theory for biomedical wearable devices.
xxue5@ncsu.edu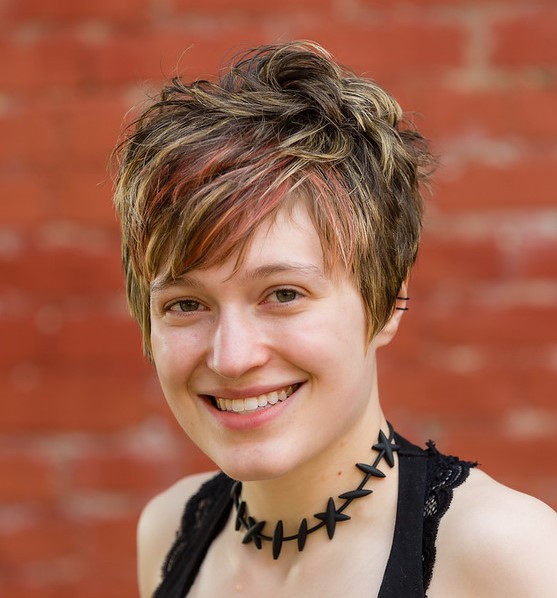
Krysten Lambeth, PhD
Postdoctoral Research Associate
B.S. in Mathematics, Salem College (2019); Ph.D. in Biomedical Engineering (2025) in the Sharma Lab, with a dissertation on muscle-aware, safe, data-driven model predictive control of a hybrid exoskeleton using ultrasound-derived fatigue and volition metrics.
kflambet@ncsu.eduPhD students
Vidisha Ganesh
PhD, Biomedical Engineering
B.S. in Computer Science, Rice University. Vidisha explores how functional electrical stimulation can be combined with limb exoskeletons to assist people with neuromuscular disorders.
vganesh3@ncsu.edu
Noor Hakam
PhD, Biomedical Engineering
B.S. in Biomedical Engineering and Political Science, NC State (2022). Noor develops real-time image processing techniques to determine movement intent and provide feedback for exoskeleton and FES control.
nzhakam@ncsu.eduAmirhossein Asadi
PhD student
Amirhossein is a PhD student in the Sharma Lab working on closed-loop control for neurorehabilitation.
Kaleigh Spencer
PhD, Biomedical Engineering
B.S. in Biomedical Engineering, Trinity College. Kaleigh joined the lab in 2026 as a Dean’s Doctoral Fellow. She brings experience in animal surgery and neurophysiology, and her research focuses on implanted neuromodulation to restore lower-limb function.
Doctoral alumni
Mayank Singh2025
Postdoctoral Researcher, Columbia University
Towards intelligent hybrid neuroprostheses: data-driven Koopman predictive control with wearable physiological sensing for gait assistance
Ashwin Iyer2023
Delsys, MA
Real-time integration of ultrasound imaging-derived muscle contractility in closed-loop control of FES and a powered exoskeleton
Ziyue Sun2022
Meta Labs
Robust model predictive control of functional electrical stimulation for human limb tracking
Qiang Zhang2021
Assistant Professor, Mechanical Engineering, University of Alabama
Ultrasound imaging and surface EMG-based voluntary effort prediction and control strategies for ankle assistance
Zhiyu Sheng2021
Postdoctoral Fellow, School of Medicine, University of Pittsburgh
Ultrasound imaging for assessment of muscle contractility and estimation of FES-induced fatigue in a hybrid neuroprosthesis

Vahidreza Molazadeh2020
Postdoctoral Fellow, NIH Clinical Center, Bethesda, MD
Iterative learning control methods for hybrid wearable robots
Xuefeng Bao2019
Visiting Assistant Professor, University of Wisconsin–Milwaukee
Robust and adaptive optimal control methods for a hybrid neuroprosthesis

Naji Alibeji2017
Senior Development Engineer, Acutronic USA, Pittsburgh, PA
A human motor control-inspired control system for a walking hybrid neuroprosthesis

Nicholas Kirsch2016
Senior Robotics Engineer, IAM Robotics, Pittsburgh, PA
Control methods for compensation and inhibition of muscle fatigue in neuroprosthetic devices
Master’s alumni
- Surendar Kotte’21Investigating the effect of sensory neurons in the propagation of tremor
- Abdullah Ahmad’21Variable step length control for a hybrid neuroprosthesis using dynamic movement primitives and model predictive control
- Zunding Xiao’18State estimation of an acoustic bubble-powered microswimmer from ultrasound imaging data
- Albert Dodson’17A novel user-controlled assisted standing control system for a hybrid neuroprosthesis
- Ziyue Sun’17Robust model predictive control of an input-delayed functional electrical stimulation
- Tianyi Qiu’16Robust compensation of electromechanical delay during neuromuscular electrical stimulation of antagonistic muscles
- Qiang Zhong’16A state-dependent coefficient-based state estimator for FES-elicited tasks · now Assistant Professor, Iowa State University
- Brian Doll’15Optimization of neuromuscular electrical stimulation to reduce muscle fatigue during isometric contractions
Undergraduates
- Sophia Francesca Lazo
- Reagan Parks
- Ryan Moloney
- Akshar Patel
- Ashlyn Gibbs
- Eugene Shon
- Collin Dulin
Join the lab
We’re always interested in hearing from motivated students and postdocs in controls, robotics, and neuroengineering.